Estimate Scattered Data
The Estimate Scattered Data options are intended for interpolating and extrapolating scattered data. Gridded data can also be processed, although in general, the Estimate Gridded Data option is recommended when the data exist in a regular grid format.
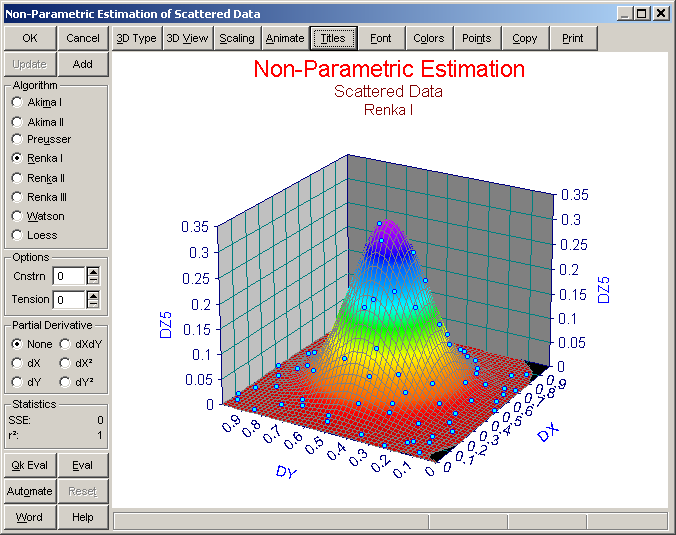
This option creates an output object as opposed to an XYZ data object when added to the notebook in the TableCurve 3D explorer. If needed, XYZ data files can be created in the Eval option and subsequently added as data sources.
To smooth data prior to non-parametric fitting, use the Smooth Loess option in the Table menu.
Algorithms
Eight different algorithms are available:
Interpolation and Smoothing
The first seven algorithms are strictly interpolation routines whose surfaces pass exactly through the data. The Loess algorithm is the only procedure that actually smoothes the data. It is furnished in this option so that smoothed estimations can be directly explored.
Continuity of Partial Derivatives
Interpolation routines are often classified as Cn where n is the number of times the interpolated surface is continuously differentiable.
A C0 procedure produces a continuous but not a smooth surface. Derivatives are discontinuous.
A C1 procedure produces a smooth surface as well as continuous first order partial derivatives.
A C2 procedure produces a smooth surface, smooth first order partial derivatives, and continuous second order partial derivatives.
A C3 procedure produces a smooth surface, smooth first and second order partial derivatives, and continuous third order partial derivatives.
The algorithms generally use a C1 interpolant. The Watson algorithm includes a non-tension C0 interpolant. The Preusser, Renka II, and Renka III algorithms furnish a C2 interpolant. The smoothness of a surface or its partial derivatives is not, however, strictly a product of the order of the interpolant. A successive gradient approach can be used to extend smoothness to higher order derivatives. Such an approach makes it possible for the Renka I procedure to offer a C3 behavior in an overall sense. The surface, first order partial derivatives, and second order partial derivatives each exhibit a very desirable C1 smoothness.
Since the Renka I algorithm is used as the interpolant in Loess procedure, the Loess interpolated surfaces also offer smooth first and second partial derivatives.
Smoothness and Rounding at Nodes
A C2 interpolant will introduce more rounding at the nodes than a C1 interpolant. A C0 surface will generally have discontinuities in the first partial derivatives at the nodes (no rounding occurs). A C2 surface can be considered "smoother" than a C1 surface even though both produce a smooth continuous surface that passes exactly through the data. Also a higher order C1 interpolant (such as the Akima quintic) can be considered "smoother" than a C1 interpolant of lower order (such as the Renka I cubic). If maximum smoothness of the interpolant is important, the Preusser C2, Renka II C2, and Renka III C2 algorithms are recommended. If minimum rounding at the nodes is sought, as in a volumetric determination of topographical data, the Watson C0 procedure should be used.
Extrapolation
All of the algorithms offer extrapolation. With the exception of the Watson C0 procedure, all of the algorithms use a C1 extrapolant. This means that there will be a smooth extrapolated surface and continuity in the extrapolated first partial derivatives. This C1 property is generally preserved across the boundary between interpolation and extrapolation. As such, there will be a smooth transition between the interpolated and extrapolated regions of the surface. In the case of the Renka I procedures, a smooth transition between extrapolated and interpolated regions will also be present for both first and higher order partial surfaces.
Interpolation Boundaries
In a scattered data algorithm with non-gridded data, the interpolation boundary is not likely to be a rectangle formed by the minimum and maximum values of the X and Y variables. In triangulation routines, the bounds which consist of the outermost shell of triangle line segments are referred to as the convex hull of the data. For the Watson procedure, the interpolation bounds are associated with the union of the set of natural neighbor circles. The Renka II and Renka III procedures have a fuzzy transition into regions of extrapolation since they are a nearest neighbor form of algorithm. In general, the triangulation-based procedures (Akima I, Akima II, Preusser, Renka I) have an abrupt transition into a region of extrapolation. For a nearest neighbor procedure, interpolation and extrapolation are usually identical.
Unique Data
The algorithms require unique X,Y values. To accommodate this, TableCurve 3D automatically averages the Z values for X,Y replicate pairs before input to the algorithms. Only exact matches in X,Y pairs are averaged. Unlike parametric fitting, two virtually identical X,Y pairs with wildly different Z values can create havoc in a non-parametric interpolation algorithm since the surface must pass exactly through both points. The Akima I, Watson, and Loess algorithms can generally deal with such nearly identical XY pairs. The other algorithms cannot.
Accuracy
Extensive accuracy testing was conducted on these specific procedures. Please refer to:
R. J. Renka and R. Brown, "Algorithm 792. Accuracy Tests of ACM Algorithms for Interpolation of Scattered Data in the Plane", ACM Trans. Math. Software, Vol. 25, No. 1, Mar. 1999, pp. 78-94.
The data used for this study are included in the SAMPLE.XLS file included with the distribution.
The accuracy of scattered data algorithms cannot be directly correlated with the order of the interpolant. In general, the Akima II procedure was most accurate. The triangulation algorithms with a global gradient procedure (Renka I, Preusser C1, Preusser C2) were most accurate with surfaces that contained multiple features. Extremely demanding surfaces were most accurately rendered with the Renka II or Renka III nearest neighbor algorithm since it can localize the fit of individual features within the data.
Surface Type
The Partial Derivative option allows for the following surfaces:
- None - the actual interpolant
- dX - the first partial derivative with respect to X
- dY- the first partial derivative with respect to Y
- dXdY- the partial derivative with respect to both X and Y
- dX2- the second partial derivative with respect to X
- dY2- the second partial derivative with respect to Y
You may observe significant differences in partial derivative surfaces between the various algorithms. In general, the Preusser C2, Renka II C2, and Renka III C2 procedures will produce the most accurate first order partial derivatives since these consist of analytic derivatives of the C2 interpolant. The first partial derivatives from these algorithms will be smooth within the data region and continuous at the interpolation-extrapolation boundary and beyond. The second partials are also analytic derivatives that exhibit a continuous surface within the data region, although smoothness and accuracy will be lacking.
The Renka I and Loess procedures use a successive gradient approach for rendering the partial derivatives. Since the interpolation is directly done upon gradient data, the surfaces produced by these algorithms will be completely smooth even for the higher order partials and at the extrapolation-interpolation boundaries and beyond. The second partial derivative surfaces of the Renka I algorithm are likely to be the most accurate. Very good accuracy is also achieved in the first order partial derivatives.
The Akima I, Akima II, and Preusser C1 procedures use analytic derivatives of their C1 interpolants. The Renka II C1 algorithm uses analytic derivatives for the first order partials and numeric derivatives for the second order partials. The Watson algorithm uses exclusively numeric derivatives. When numeric derivatives are used, rapidly changing regions of surfaces with discontinuous derivatives can produce single spikes in higher order derivatives that overwhelm the rest of the data. Regardless of whether the derivatives are numeric or analytic, the higher order derivatives of a C1 interpolant are not continuous and should be regarded as unreliable.
Statistics
For the Loess procedure, where smoothing occurs, the surface will not pass exactly through the data. To enable the results of a non-parametric Loess to be compared with parametric fits, a squared sum of residuals (SSE) and a coefficient of determination (r2) are displayed.
For the interpolation procedures, no computation is made and the SSE is set to 0 and the r2 is set to 1.
The Watson procedure also displays a zero SSE even though it adds a tiny random perturbation to data nodes to insure unique natural neighbor circles. In its case, the r2 will be 1 to about 8-10 decimal places and the SSE will be 0 to only about half of machine precision. Due to this aspect of the algorithm, the Watson procedure reproduces the z at the nodes to about 7-8 significant digits instead of the full 15.
Evaluation
The Eval button is used to open a full featured evaluation procedure. Individual values for function, partial derivatives, roots, and volumes can be computed. This option can also be used to generate a table based upon a uniform grid or X,Y columns of input data originating from any of TableCurve 3D's supported formats.
Note that this Generate Table option in the Evaluation is the only way to convert data to a partial derivative for subsequent parametric fitting.
Real-Time Evaluation
The Quick Eval option offers the means to evaluate a few basic properties of a surface in a real time as algorithms and settings are changed. Simply enter an X and Y value in order to have a Z computed automatically with each change in the surface.
Since optimizations are such an important part of surface science, the Surface Min and Surface Max check boxes allow for the display the X,Y,Z coordinates of the minimum and maximum of the surface. These are found by a two dimensional minimization algorithm that seeks 1E-8 fractional precision. Note that the minimum and maximum computations may be extremely slow with the Akima I procedure since it is very inefficient with individual function evaluations.
Graph Controls
This option offers the common TableCurve 3D graph controls:
Add
 The Add button adds an Estimate Scattered Data object to the currently selected XYZ data object in the TableCurve 3D explorer. This is an output object that can be added to any item containing XYZ data, although data that are scattered in the XY plane are recommended.
Update
If an Estimate Scattered Data item is currently selected and the main graph is clicked, the Update button will be enabled. This updates the non-parametric fit with the current settings as well as updating all graph customizations.
Batch Automation
The Automate button activates the TableCurve 3D Automation facility. This allows unattended processing of large numbers of data sets. The data sets can be consolidated in an Excel file or acquired using a DLL. The graphs and reports can be exported to a Microsoft Word/RTF file, while the processed data can be exported to an Excel 95 or Excel 97/2000/XP file.
If an Automation session is in progress, the Reset button can be used to terminate the automated processing.
MS Word/RTF Export
The Word button is used to save the current graph to either a MS Word file or a portable RTF (Rich Text Format) file. The graph is inserted into the file as a Windows metafile.
Preserving the Current Interpolation Settings
Exit with OK to update the procedure's settings. These values will be reflected the next time the procedure is entered. To discard the current settings, close the procedure with the Cancel button. Note that the Add or Update options must be invoked before closing the dialog in order for the non-parametric output to be added to the current notebook.